2025 / Project
Domestic Mobile Robot
A complete ROS 2 navigation pipeline for a simulated service robot, from custom robot design and SLAM to Nav2 patrol analysis.
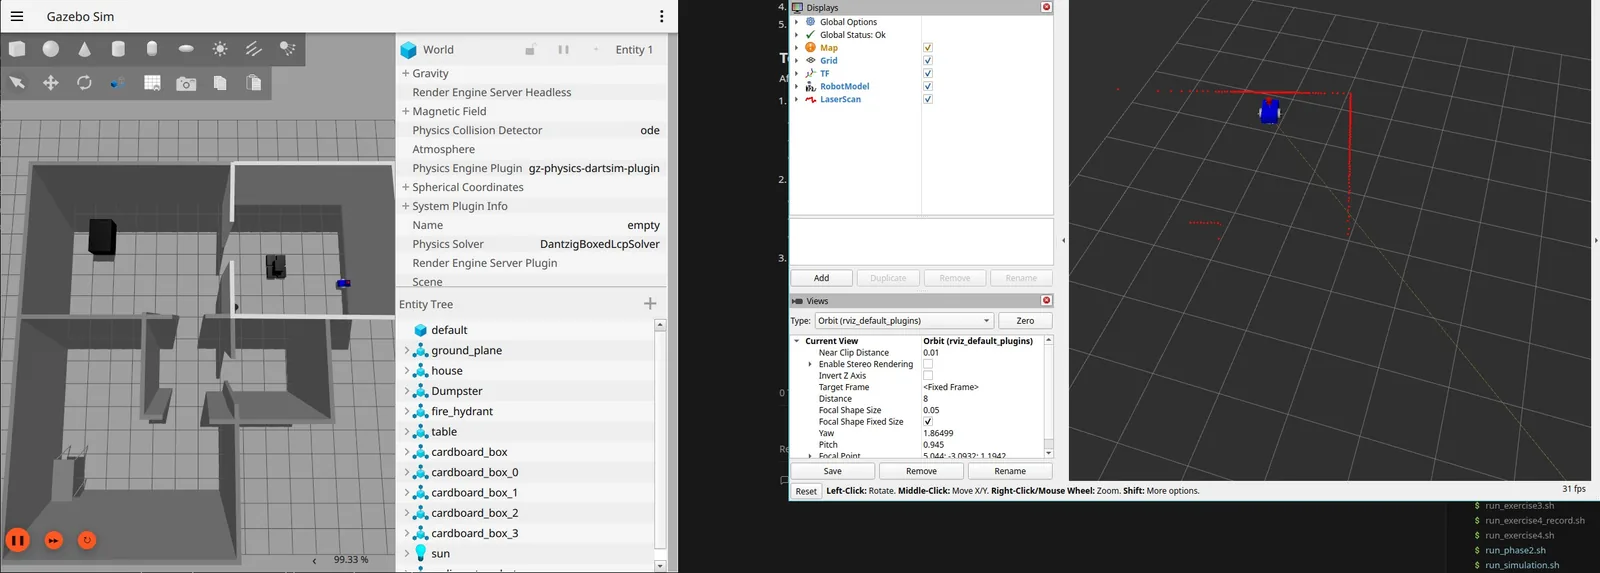
I designed a custom differential-drive domestic robot and built the full autonomy stack around it: simulation, sensing, state estimation, mapping, localization, navigation, waypoint patrol, recording, and offline analysis.
The robot combines 2D LIDAR, an IMU, wheel odometry, Extended Kalman Filtering, SLAM Toolbox, AMCL, Nav2, and a modular ROS 2 launch architecture. The project progressed deliberately through six phases so each subsystem could be validated before integration.
Engineering lessons
A wall that wasn’t there
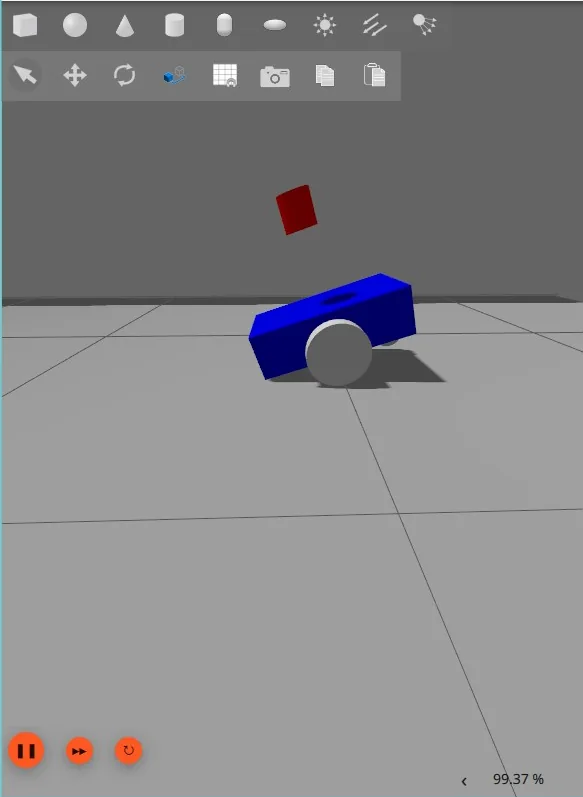
One issue was a false wall appearing in the map. When the simulated robot braked, its chassis pitched forward and the LiDAR hit the ground. Changing the sensor range could hide some of those detections, but the robot would still be pitching. Adding a front caster stabilized the chassis and dealt with the cause.
One publisher per transform
The ROS components also had to agree on where the robot was. The EKF publishes odom → base_link and AMCL publishes map → odom. Each of those relationships needs exactly one publisher; otherwise every component can be running while giving conflicting descriptions of the robot’s position.
AMCL parameters and Nav2 lifecycle behaviour were then tuned for the waypoint patrol.
Replaying the patrol
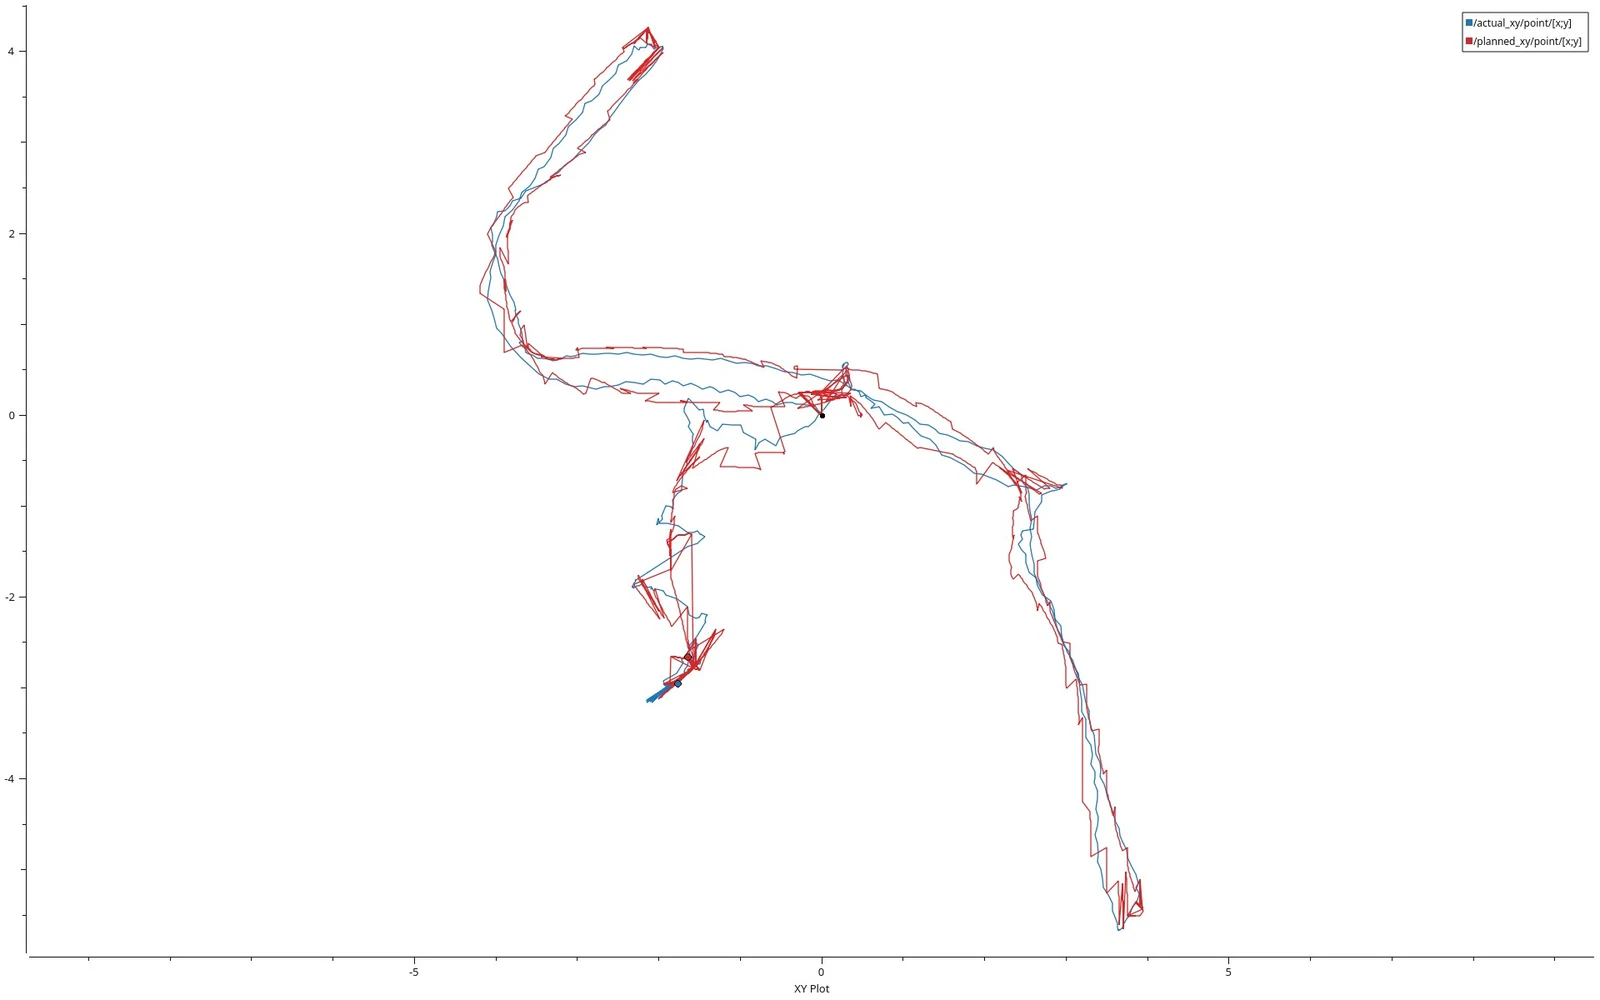
For the patrol analysis, I compared the planned path with filtered odometry transformed into the map frame. The frame and the playback clock had to line up for that comparison to mean anything.
Playback brought up a separate issue: the wheels appeared detached from the robot in RViz, because the recording didn’t include the dynamic joint states needed to display them. A separate robot description for analysis treats the wheel joints as fixed, so the robot can be shown with the data that exists. That fixed the display; it didn’t recover the missing wheel-motion measurements.
The final analysis measured a 0.15 m mean path deviation over the recorded patrol and documented the remaining map–odom jitter under wheel-slip conditions. The public repository includes the ROS 2 workspace, robot description, environments, launch scripts, maps, patrol metadata, exercises, and report sources.
Checking against hardware
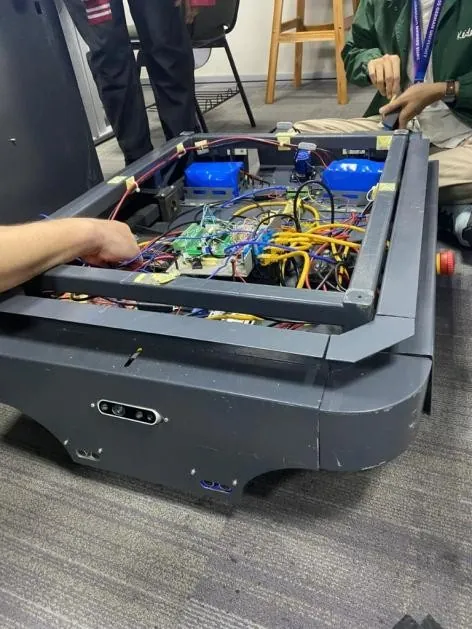
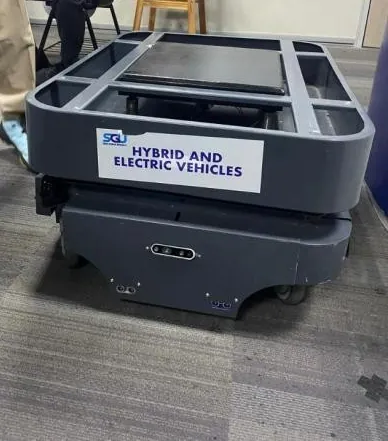
The project itself was built and analysed in simulation. Alongside it, we tested the software on an autonomous mobile robot available in SGU’s lab, to check that what worked in Gazebo also held up on real hardware.
Related work
All projectsCase study: Human-reviewed AI document workflows
How I built AI tools that read operational documents while keeping a person responsible for every record that matters. A two-minute read.
View project
CAD-Integrated KST Assembly Rating Tool
A verified Python and Fusion 360 workflow for analyzing how assembly features constrain rigid-body motion.
View project